
Atomic Skull
Well-known member
- Messages
- 788
- Reaction score
- 751
- Points
- 248
So I have a couple complete airframes a whole pile of parts for my existing machines, and enough electronics (except for the ESC) to get a second one flying along with several spare sets of blades. So I figured why not.
Cyclic servos are AFRC, 0.4 sec 60 degrees and 25kg-cm and the tail servo is 0.35sec 60 degrees and 22kg-cm. They can run in narrowband mode up to 666hz.
Flight controller is a Radiomaster Nexus, Amain sold them off at a ridiculously low $38 when the newer Nexus X was released, the only difference is that the X version has 9 ports instead of 7. It runs on the open source Rotorflight software.
ESC will be a SEQURE 14200 Pro, it can run either ESCape32 or AM32 firmware. Helidirect sells them with an AM32 tuned by their team pilots for use on large helicopters so that it is plug and play.
Motor will be a Quantum 4530 450KV outrunner I have laying around.
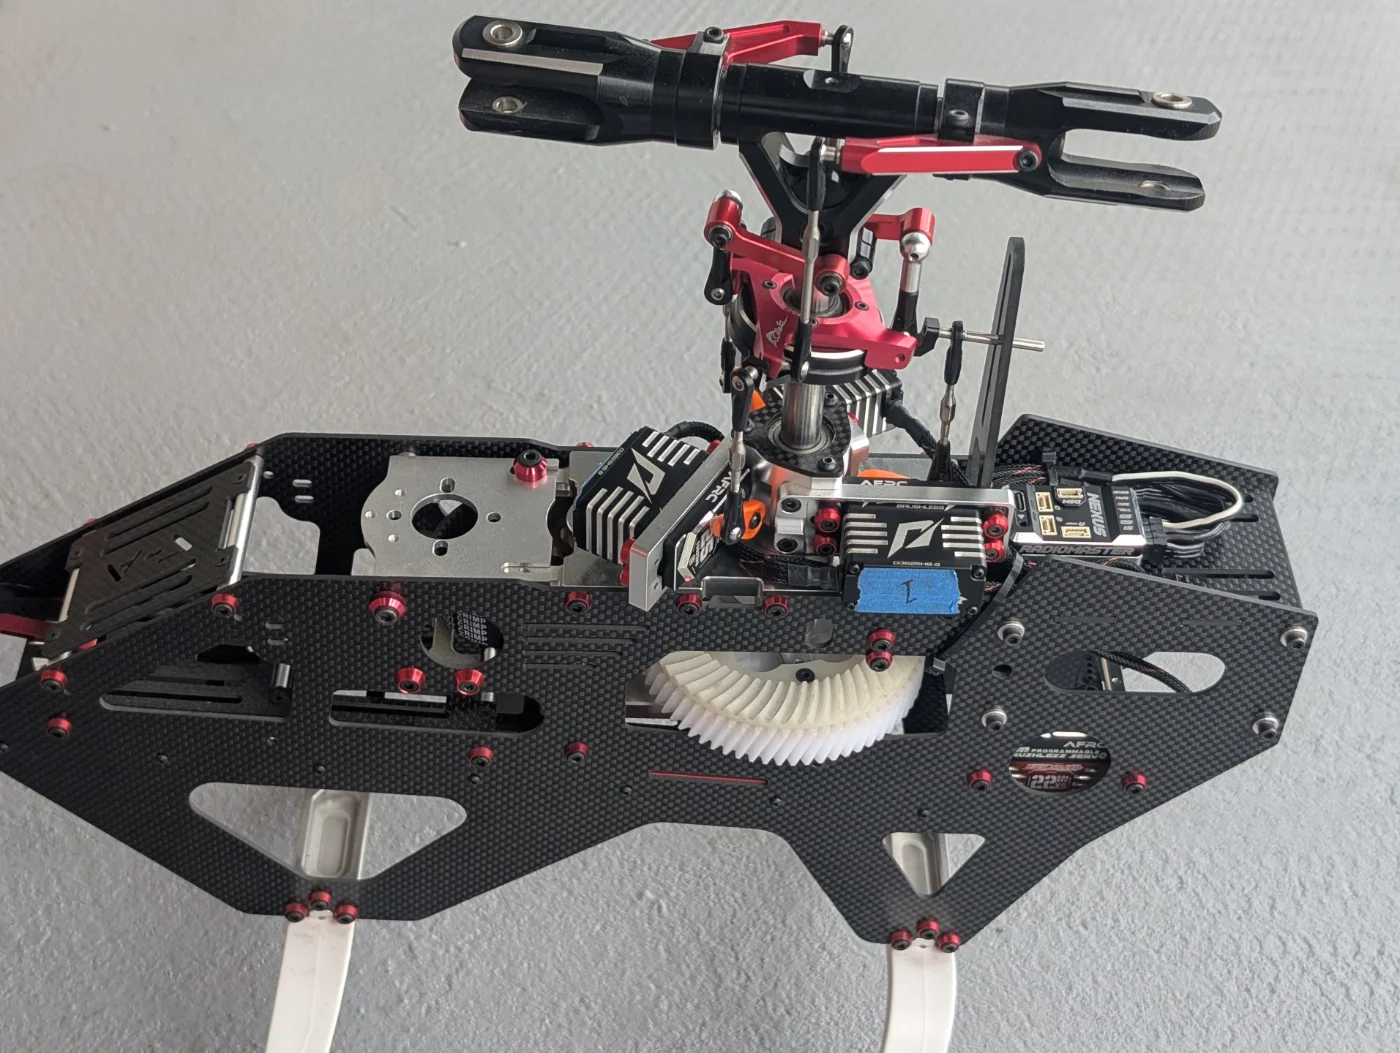
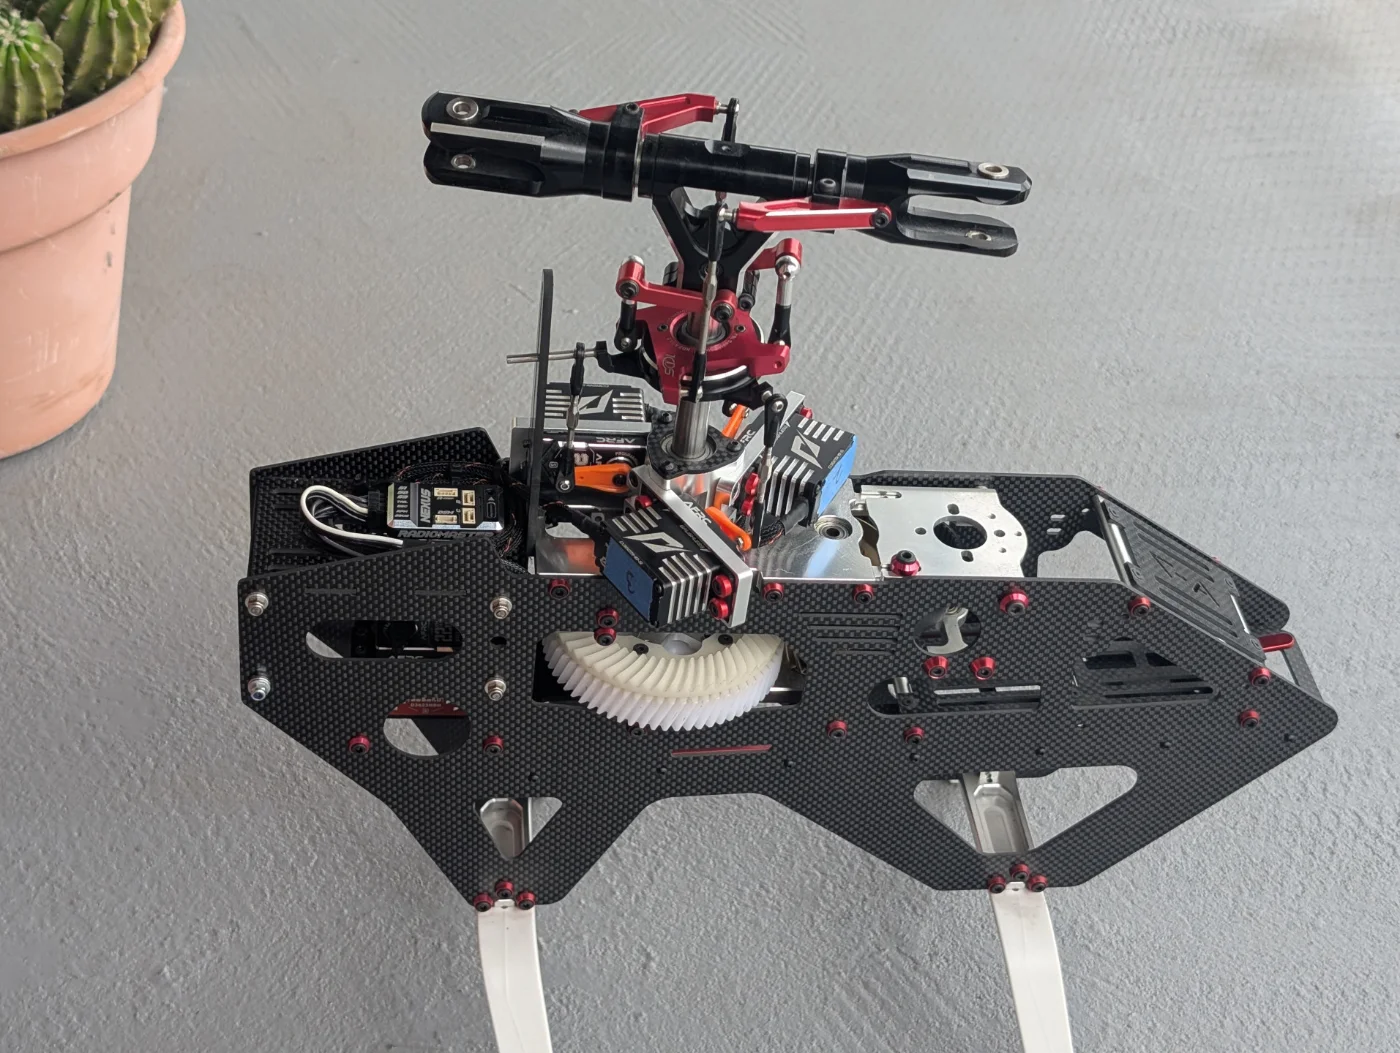
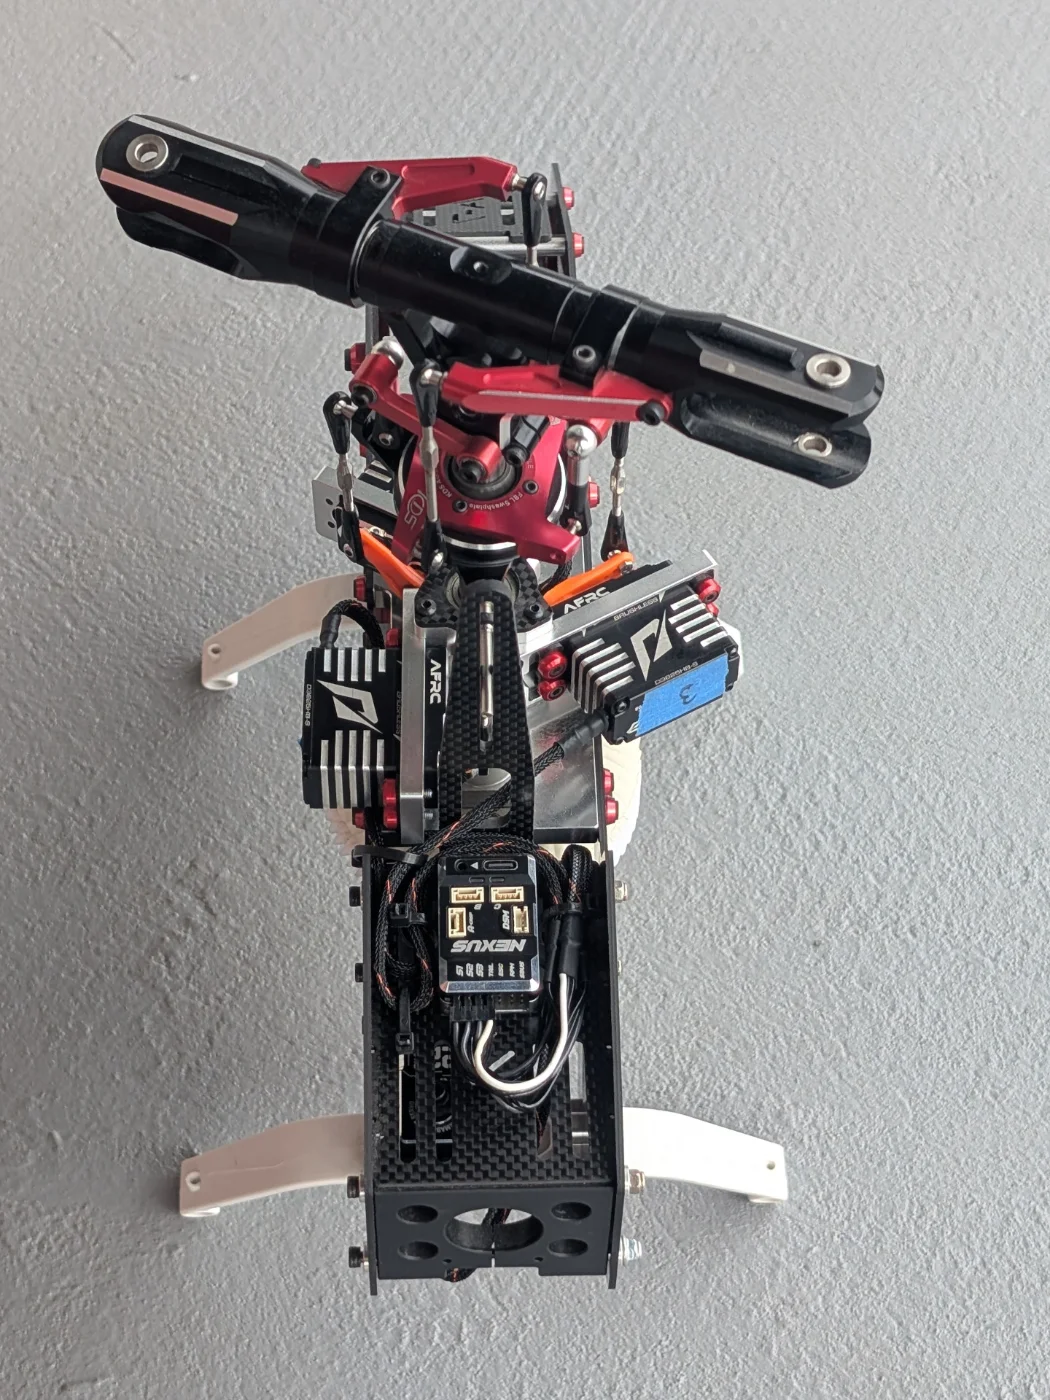
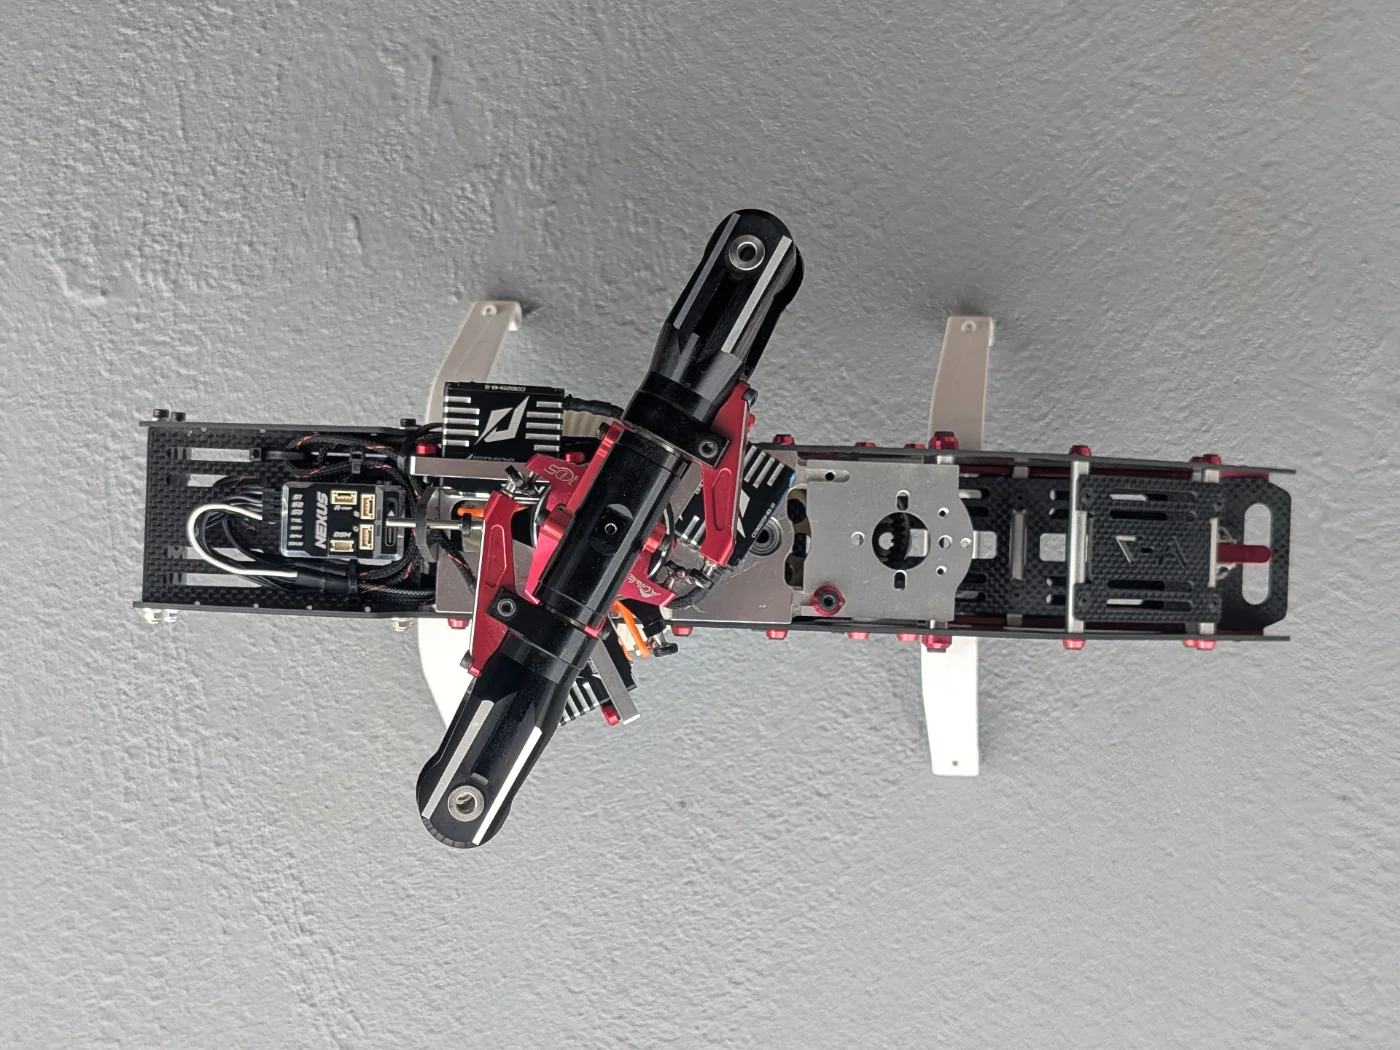
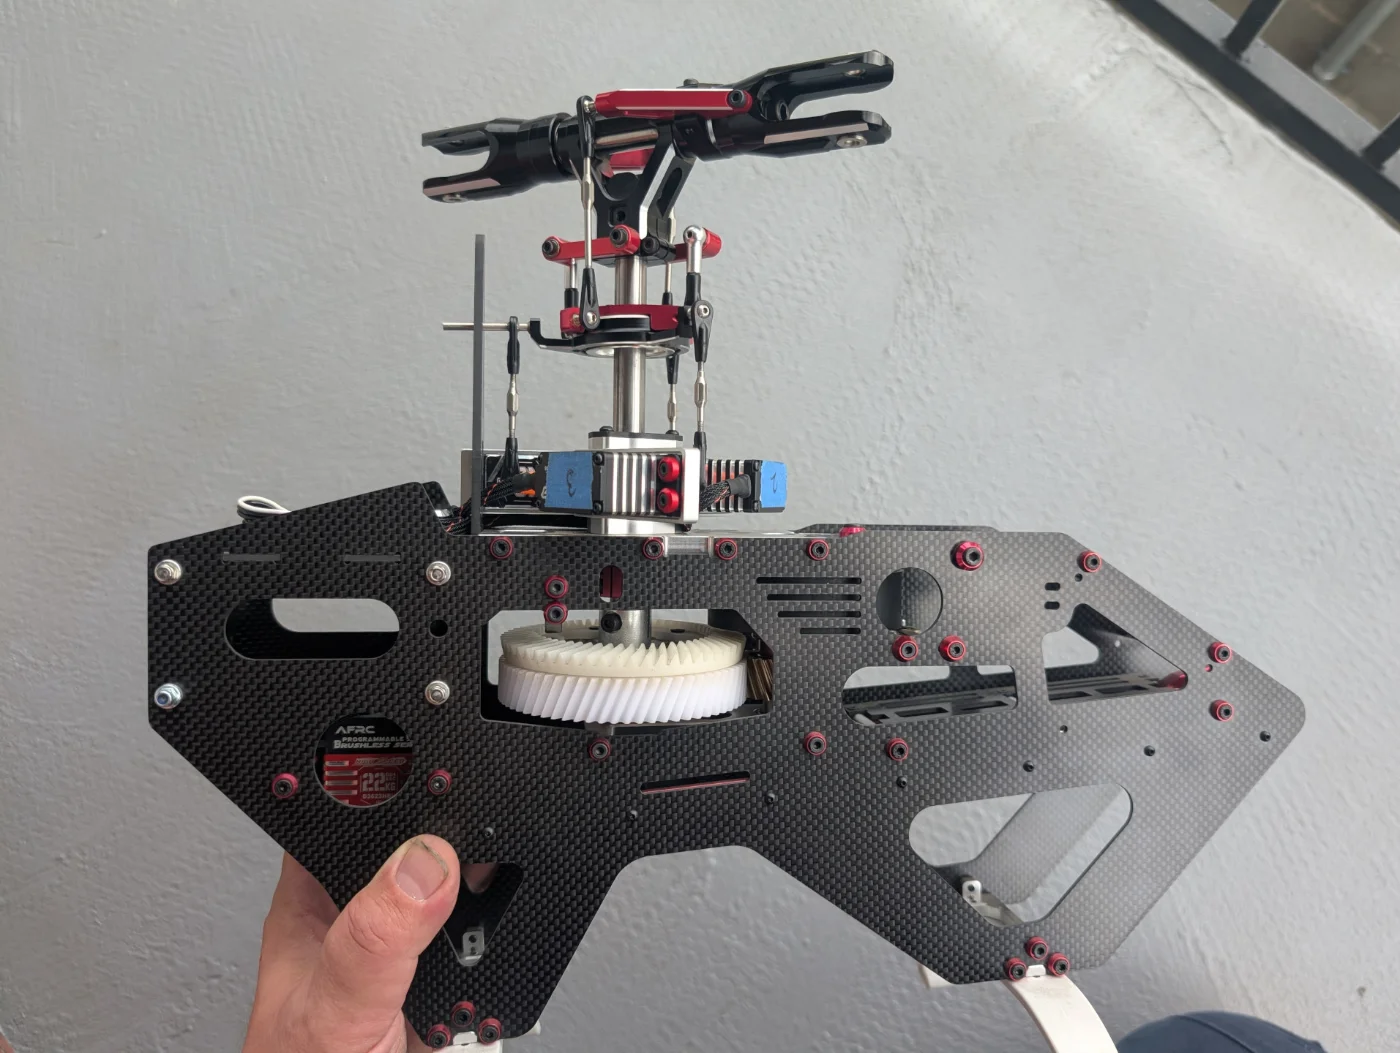
Have the servo wiring done and the servos centered and head geometry set up, waiting on the ESC now.
Cyclic servos are AFRC, 0.4 sec 60 degrees and 25kg-cm and the tail servo is 0.35sec 60 degrees and 22kg-cm. They can run in narrowband mode up to 666hz.
Flight controller is a Radiomaster Nexus, Amain sold them off at a ridiculously low $38 when the newer Nexus X was released, the only difference is that the X version has 9 ports instead of 7. It runs on the open source Rotorflight software.
ESC will be a SEQURE 14200 Pro, it can run either ESCape32 or AM32 firmware. Helidirect sells them with an AM32 tuned by their team pilots for use on large helicopters so that it is plug and play.
Motor will be a Quantum 4530 450KV outrunner I have laying around.
Have the servo wiring done and the servos centered and head geometry set up, waiting on the ESC now.
Last edited: